IEEE RAS UT RoboMaster
ArUco Robot Localization
Or watch on YouTube.
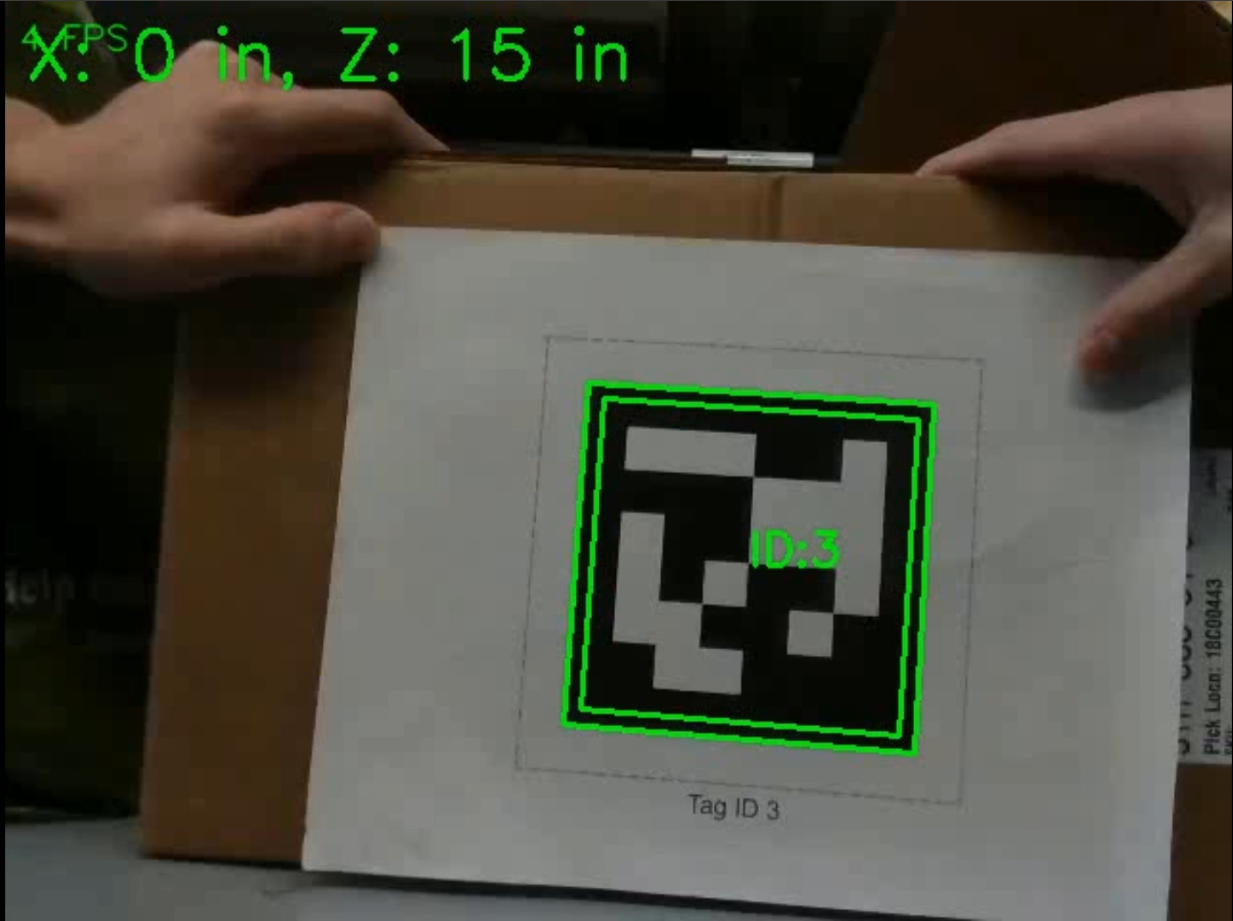
A camera-based localization system in C++ that estimates the robot’s position to
within 4 cm on a 12×8 meter playing field. It detects ArUco tags with
OpenCV and feeds the resulting estimates into the robot’s ROS2 stack. Webcam runs
recorded with ros2 bag meant the pipeline could be replayed and tuned
without the robot, and the whole environment ran in Docker so it behaved the same on
every machine.